What low-light performance should an OEM night vision dash cam meet?
Key Takeaways
- What low-light performance should an OEM night vision dash cam meet?Automotive Tech Analyst
- Adipic Acid CAS 124-04-9 Market Trends: Why Buyers Are Rebuilding Supply PlansLead Materials Scientist
- How technology forecasting can reduce investment risk in cloud infrastructureIT & Security Director
- How to size DC fast EV charging stations for peak charging demandIT & Security Director
- When does modular construction reduce a project's total cost?Chief Civil Engineer
- What cloud infrastructure analysis reveals about Singapore latency risksIT & Security Director
- How to verify recycled green building materials meet project standardsChief Civil Engineer
- What to evaluate when comparing cybersecurity analysis providersIT & Security Director
Industry Overview
We do not just publish news; we construct a high-fidelity digital footprint for our partners. By aligning with TNE, enterprises build the essential algorithmic "Trust Signals" required by modern search engines, ensuring they stand out to high-net-worth buyers in an increasingly crowded global digital landscape.
For an OEM night vision dash cam, “good low-light performance” should mean that the recorded file retains decision-useful evidence when illumination falls, changes abruptly, or becomes uneven. A bright-looking preview is not enough. Technical evaluators should require the platform to preserve readable roadway context, vehicle motion, light-source control, and enough detail to support event review under the operating conditions the product is meant to serve.
There is no single minimum lux figure that defines an acceptable unit across every dash cam program. A camera intended for urban consumer vehicles, a fleet recorder operating overnight, and an ADAS-adjacent commercial platform face different exposure times, mounting positions, motion patterns, and evidential requirements. The specification should therefore be built around repeatable scenes and measurable outputs, rather than a supplier's “night vision” label or a sensor datasheet sensitivity number.
Start with the evidence the recording must retain
Low-light requirements should begin with an operational question: after an incident, what must a reviewer be able to determine from the clip? In many applications, the answer includes lane position, road edges, traffic-signal state, direction of travel, nearby vehicles, pedestrians or cyclists, and the sequence leading to impact. License-plate visibility may also be required, but it needs to be specified carefully. A plate on a stationary vehicle under a streetlamp is a far easier target than a plate on an oncoming vehicle at closing speed with LED headlamp glare.
This distinction matters because dash cam image quality is constrained by physics as much as camera tuning. In darkness, the system can increase gain, lengthen exposure, apply stronger noise reduction, or illuminate the scene with infrared. Each action has a cost. More gain increases image noise; longer exposure introduces motion blur; aggressive noise reduction can remove fine edges and character detail; infrared performance depends on range, reflectivity, windshield transmission, and whether the scene is captured through glass.
An OEM requirement should separate essential evidence from aspirational detail. It may be reasonable to require a forward-facing camera to show a vehicle's trajectory, road geometry, and nearby hazards on an unlit road. Requiring legible plates at highway speed in the same scene may demand a more specialized optical and processing design, and may remain conditional on distance and relative motion. Combining both expectations into a broad “full HD night vision” claim usually produces disputes later in validation.
Specify the scene, not just the sensor
Sensor format, pixel size, aperture, and image signal processor capability all influence dark-scene performance, but none of them proves final recording quality in a vehicle. The windshield changes the optical path. Dashboard reflections appear. Wiper sweep, rain, mist, dirt, vibration, compression, and power-state transitions affect the saved footage. A useful OEM specification defines the installed camera system and the recording outcome.
At minimum, the evaluation set should include the following conditions:
- Unlit or lightly lit roads with the vehicle's low-beam headlights operating.
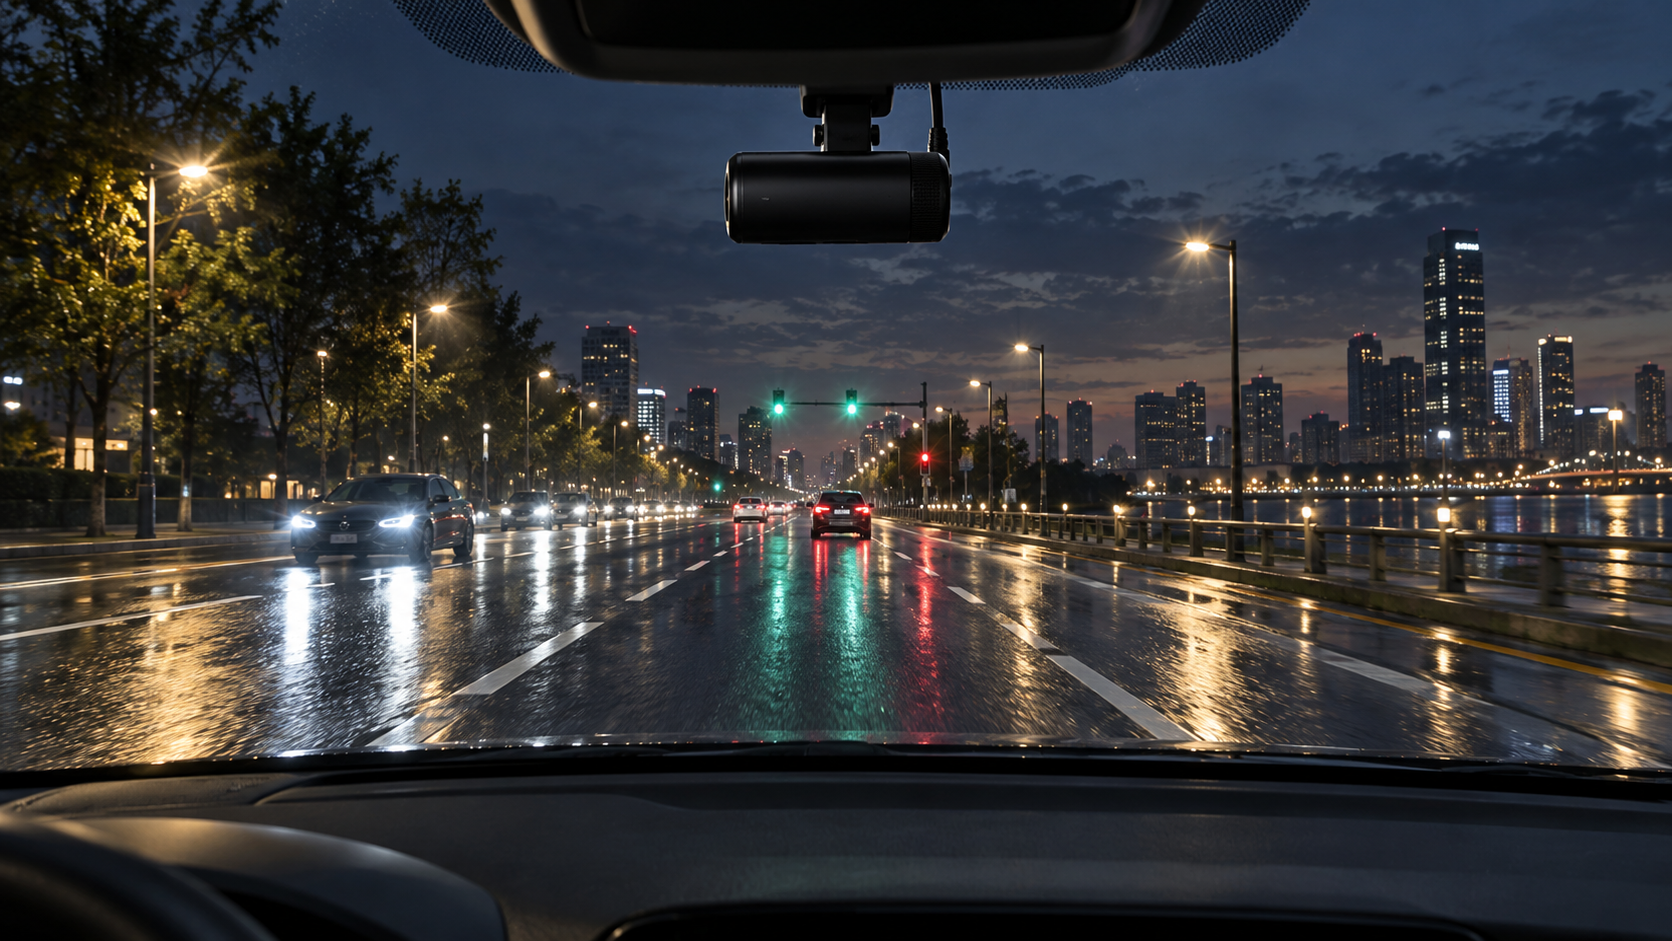
- Urban roads containing bright shopfronts, streetlights, signal lamps, and darker pedestrian areas.
- Oncoming traffic with LED or high-intensity headlamps entering the field of view.
- Transitions into and out of tunnels, parking structures, covered loading areas, or dawn and dusk environments.
- Wet roads, rainfall or spray, where reflections and droplets change contrast and trigger flare.
- Vehicle vibration and realistic speed, because static low-light imagery can conceal motion-blur failures.
For each scene, define the camera mounting position, windshield type and condition, vehicle lighting state, recording resolution, frame rate, codec settings, and the expected distance to relevant objects. A supplier demonstration using a camera mounted outside the vehicle, pointed at a controlled target, should not be treated as equivalent evidence for an in-cabin installation.
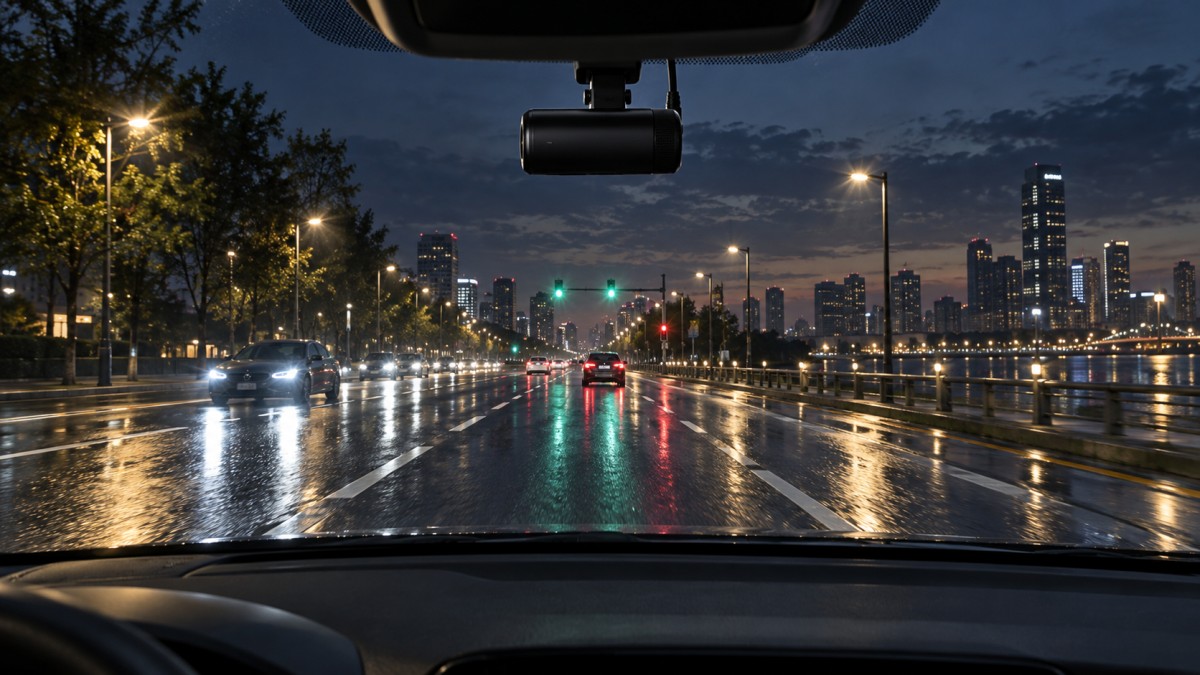
Illuminance values can still be useful as test controls, especially when comparing iterations of the same design. They should be recorded at the relevant target plane, together with scene lighting geometry. However, lux alone is incomplete. Two scenes with the same measured illumination can produce very different recordings because one contains a direct headlamp, reflective signage, wet asphalt, or a high-contrast background. The test report needs both controlled measurements and representative video clips.
Assess exposure, blur, and dynamic range together
Many poor night recordings result from an exposure strategy that appears effective in a static scene. When the camera extends shutter time to brighten dark areas, the road may look clearer in a stopped-vehicle preview, while moving objects become smeared once the vehicle is in motion. The image can still be visually bright but offer little reliable detail at the point of an incident.
Evaluators should review frame-by-frame recordings at representative speeds. Look for the point at which lane markings, vehicle outlines, pedestrians, traffic signals, and text-bearing objects lose usable definition. It is also useful to compare clips obtained under the candidate's default tuning and any alternative night mode. If a supplier offers a selectable “enhanced night” setting, establish whether that setting will be enabled in production, how it is triggered, and whether it changes frame rate, bitrate, or event-recording behavior.
Dynamic range is equally important. A dash cam operating at night often sees a nearly black road and an intensely bright headlamp in the same frame. The desired result is not simply suppression of the bright area. The camera should control blooming, flare, and exposure pumping while retaining context in darker portions of the scene. If the system closes exposure every time an oncoming vehicle appears, the road edge and pedestrian zone may disappear. If it prioritizes shadow lift without controlling highlights, headlamps and illuminated signs can overwhelm nearby detail.
High dynamic range functions should therefore be evaluated in motion and in recorded output, not assumed from the presence of an HDR or WDR feature in a component list. Some multi-exposure approaches may create artifacts where objects move between exposures. Tone mapping may make a video appear more attractive on a display while reducing local contrast needed for evidence review. Compression can further obscure the benefit if bitrate or encoder behavior is poorly matched to noisy dark scenes.
Questions that expose weak low-light claims
- Does the supplied sample clip come from the exact sensor, lens, ISP version, firmware, enclosure, and windshield installation proposed for production?
- Are shutter time, gain, frame rate, and HDR mode documented for each test condition?
- Does the system retain its normal event-triggering, audio, timestamping, and loop-recording functions in low light?
- Can the supplier provide original files rather than only re-encoded promotional footage?
- What happens to image quality when the memory card nears capacity, temperature rises, or the unit moves between day and night conditions?
Infrared can solve a specific problem, but it is not universal night vision
Infrared illumination is often valuable for interior-facing cameras. It can reveal a driver or cabin occupant in darkness without visible light, particularly when paired with an IR-sensitive sensor and suitable near-infrared LEDs. For driver monitoring, passenger documentation, or certain cabin-security functions, that can be a practical and effective design path.
Its value for forward-facing road capture is more limited. Standard automotive windshields can reflect IR emitters positioned inside the cabin, creating haze or glare in the image. The useful range of illumination also falls quickly in open-road scenes, while dark surfaces, rain, fog, and varying object reflectivity complicate results. Infrared can improve close-range visibility in selected configurations, but it does not replace headlamp-based imaging, wide dynamic range control, or a low-noise visible-light sensor for road recording.
Technical teams should also distinguish between an IR-cut filter that changes position under low illumination and a camera equipped with active IR illumination. The former may increase sensor response to near-infrared light present in the environment; it does not guarantee that the camera can illuminate the scene. Switching behavior itself must be tested. A visible color shift, focus change, exposure delay, or mechanical reliability issue during day-to-night transitions can affect the recorded record.
For an interior camera, confirm that the chosen IR wavelength, emitter placement, power management, and lens coating produce even facial visibility without hot spots. For a forward-facing camera, require the OEM to demonstrate the final through-windshield arrangement. Claims based on an open-air IR test should be treated as preliminary engineering information, not production acceptance evidence.
Do not let resolution substitute for optical performance
A higher pixel count can support more detail, but it does not create light. Small pixels, a slow lens, high noise, and aggressive compression can make a nominally high-resolution night recording less useful than a lower-resolution system with better optical throughput and exposure control. Resolution also affects storage requirements and encoder load, especially where fleets require longer retention periods or simultaneous front, rear, and cabin streams.
Review the complete image chain: sensor response, lens aperture and distortion, focus stability over temperature, image processing, encoder settings, memory-card performance, and playback software. The lens deserves particular scrutiny. A favorable aperture value can be undermined by poor edge performance, flare from bright light sources, or focus drift caused by temperature changes. A dash cam is normally fixed-focus, so the target focus range must reflect the intended evidence priorities rather than only a laboratory chart distance.
Compression should be validated on actual night footage. Noise and rain create difficult image content that can consume bitrate rapidly. When compression is too aggressive, dark regions may show block artifacts, moving objects can dissolve, and fine detail may vanish despite acceptable sensor output. Ask to inspect native files at the intended production resolution and bitrate, using the playback workflow that fleet managers, insurers, safety teams, or investigators will use.
Build an acceptance plan before approving the platform
For night vision dash cams OEM programs, the most defensible requirement is a scene-based acceptance matrix with objective and subjective criteria. Objective criteria can include recorded frame rate, timestamp continuity, exposure response time, absence of dropped frames, field of view, and defined target visibility at stated distance and motion conditions. Subjective review still has a legitimate place for assessing glare, flare, color rendering, scene comprehensibility, and whether artifacts interfere with interpretation. The reviewer group and pass/fail method should be agreed before samples are judged.
Production control deserves the same attention as prototype approval. A strong engineering sample does not guarantee stable results after a sensor revision, lens-source change, ISP firmware update, or alternate memory-card qualification. The OEM agreement should identify controlled components, firmware versioning, change-notification obligations, and the conditions that trigger revalidation. This is particularly important where a camera platform is supplied across several vehicle programs with different windshields, dashboard geometries, or electrical environments.
Temperature testing should also be tied to image outcomes. A device may remain operational at high or low temperatures while image noise, focus, IR behavior, or encoder stability degrades enough to reduce evidential value. Low-light validation needs to include the thermal range relevant to the deployment, along with start-up and recovery behavior after power interruption.
The right performance threshold is therefore not a universal “night vision” benchmark. It is a documented ability to record usable, repeatable evidence in the darkness, glare, weather, movement, and installation conditions the vehicle will face. Buyers who define those scenes early can compare OEM platforms on meaningful performance and avoid approving a camera whose night capability exists mainly in its marketing footage.
Deep Dive
Related Intelligence
 Auto ElectronicsHow Automotive Tier-1 Suppliers Validate Polyurethane Resins for Bumper Systems Under -40°C to +85°C CyclingAnalyst:Automotive Tech Analyst
 Auto ElectronicsLED headlights brighten roads — and also expose flaws in headlamp alignment protocolsAnalyst:Automotive Tech Analyst
 Auto ElectronicsCar infotainment units with Android Automotive OS struggle with OTA update rollbacks — and no clear recovery pathAnalyst:Automotive Tech Analyst