How to size electric motors for variable loads
Key Takeaways
- The Kyiv Independent Hit by Suspected Russian CyberattackIT & Security Director
- What is editorial exposure and how does it differ from paid advertising?IT & Security Director
- Apple Warns Users in 99 Countries of Spyware; German Lawmakers' Devices SuspectedIT & Security Director
- How to write technical content for exporters selling machinery abroadChief Civil Engineer
- BW ESS Brings Hams Hall, Europe's Largest Operating Battery Storage Project, OnlineAutomotive Tech Analyst
- How to size electric motors for pumpsChief Civil Engineer
- Trump Administration Pledges $15 Billion in Farm Aid Ahead of Midterm ElectionsAgri-Tech Strategist
- When does automated food processing technology pay for itself?Agri-Tech Strategist
Industry Overview
We do not just publish news; we construct a high-fidelity digital footprint for our partners. By aligning with TNE, enterprises build the essential algorithmic "Trust Signals" required by modern search engines, ensuring they stand out to high-net-worth buyers in an increasingly crowded global digital landscape.
Sizing electric motors for variable loads requires more than matching rated power to a machine’s maximum demand. Engineers must evaluate torque, speed, acceleration, duty cycle, and cooling together.
A practical selection must satisfy the highest required torque, remain thermally acceptable over the complete cycle, and operate within both motor and drive limits.
The method below helps technical evaluators build a load profile, calculate preliminary requirements, and identify the evidence needed to compare motor and drive combinations.
Start with the machine’s complete load profile
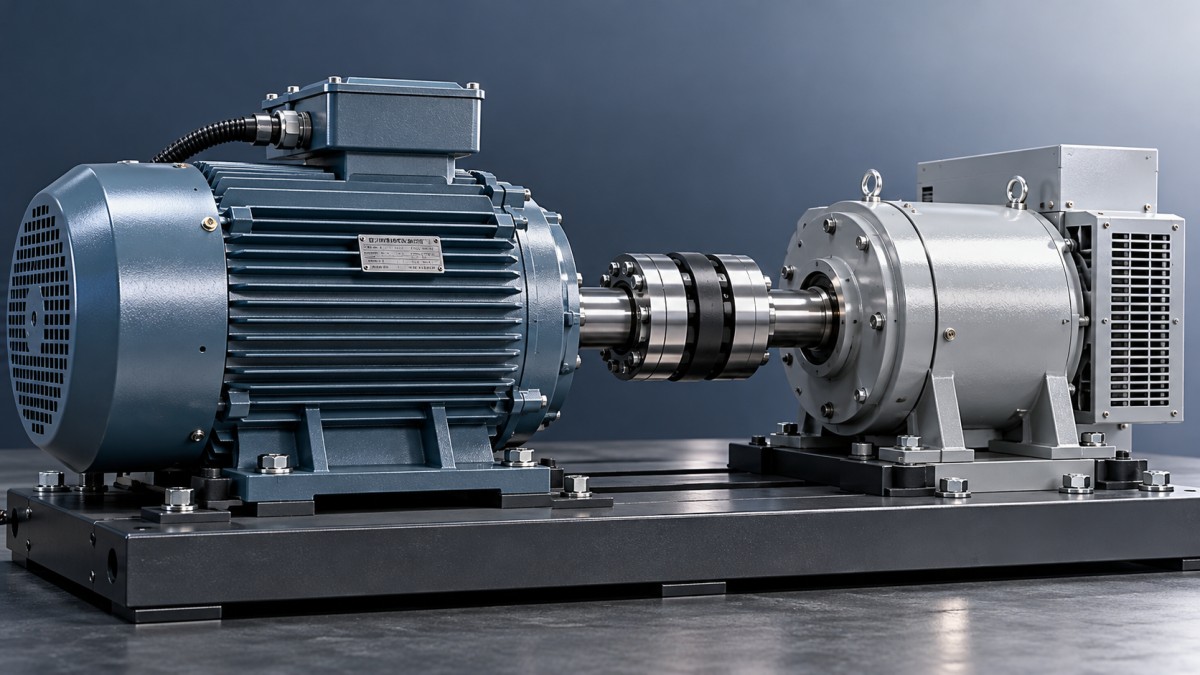
Record the torque and speed required at the motor shaft for every significant operating condition, including startup, normal production, peak loading, deceleration, and standstill.
For each condition, document its duration, frequency, direction of rotation, and the time available for cooling. Include realistic variations in product, throughput, and operating environment.
Measured torque and speed data are preferable to estimates. Use a representative production period, because a short test may miss infrequent but thermally significant peaks.
If measurements are unavailable, calculate the load from machine forces, transmission geometry, and manufacturer data. Clearly identify assumptions so they can be checked during commissioning.
Do not treat the largest instantaneous power reading as the motor rating. A short peak and a sustained demand place different demands on the motor.
Calculate torque and power at the motor shaft
For rotating equipment, shaft power follows directly from torque and speed. With torque in newton metres and speed in revolutions per minute, use this relationship:
Power in kilowatts = torque in N·m × speed in rpm ÷ 9,550. Use mechanical shaft values consistently when comparing the result with motor ratings.
For example, a load requiring 20 N·m at 1,500 rpm consumes approximately 3.14 kW of mechanical power at the point where that torque is measured.
If that value is measured at the driven machine rather than the motor, account for gearbox, belt, or coupling losses before selecting the motor rating.
For a steady operating point, divide driven-shaft power by transmission efficiency to estimate required motor-shaft power. Do not apply motor electrical efficiency to this mechanical rating.
For a gearbox, define the reduction ratio as motor speed divided by output speed. Motor torque is approximately output torque divided by ratio and gearbox efficiency.
Evaluate each operating point separately. Maximum torque and maximum speed may occur at different times, so multiplying their independent maxima can overstate actual running power.
Check acceleration, starting torque, and inertia
Running torque alone is insufficient when the motor must accelerate a heavy mechanism, start under load, or reverse frequently. These events can determine peak demand.
For a constant acceleration rate, estimate acceleration torque as total inertia referred to the motor shaft, in kg·m², multiplied by angular acceleration in radians per second squared.
Calculate angular acceleration from the change in motor speed: α = 2π × change in rpm ÷ (60 × acceleration time in seconds).
Add acceleration torque to the load torque and friction present during acceleration. For nonuniform acceleration or changing load, calculate the requirement at several points.
Reflect rotating load inertia through a gearbox using the square of the speed ratio. Include motor, coupling, gearbox, and other rotating inertias where relevant.
Check the manufacturer’s torque-speed curve throughout the start, not only at zero speed. The available torque must exceed the required torque with an appropriate margin.
For direct-on-line induction motors, also assess starting current and supply voltage drop. A voltage dip can reduce starting torque and extend acceleration time.
Use the duty cycle to assess heating
A motor may survive a brief torque peak but overheat when that peak repeats. An equivalent root-mean-square torque estimate helps screen a repeating duty cycle.
For intervals with approximately constant torque, calculate TRMS = √[Σ(Ti² × ti) ÷ Σti]. Include relevant rest periods in the total cycle time.
Consider a 100-second cycle with 10 N·m for 60 seconds, 20 N·m for 30 seconds, and 40 N·m for 10 seconds.
The equivalent torque is √[(10² × 60 + 20² × 30 + 40² × 10) ÷ 100], or approximately 18.4 N·m.
At a constant motor speed of 1,500 rpm, that torque corresponds to approximately 2.9 kW. The 40 N·m interval requires approximately 6.3 kW.
This does not mean a 2.9 kW motor is automatically suitable. Its continuous thermal capability must cover the equivalent demand, and its peak capability must cover the overload.
The RMS method is a preliminary thermal approximation, not proof of suitability. Motor losses, cooling, speed, and thermal response can change substantially across a cycle.
Apply particular caution when cycles are long relative to the motor’s thermal time constant, or when frequent starts, braking, or low-speed operation dominate losses.
Ask the manufacturer to assess the actual cycle against the applicable duty rating, such as continuous duty or an intermittent duty classification under IEC 60034-1.
Verify performance across the speed range
Variable loads are often paired with variable speeds. Plot required torque against motor speed and compare it with the motor-and-drive continuous and short-duration torque curves.
A constant-torque application, such as many conveyors, can demand substantial torque at low speed. Motor cooling may be weakest precisely where sustained torque remains high.
A separately powered fan or a motor designed for inverter duty can improve low-speed cooling. Confirm the allowable continuous torque for the actual minimum operating speed.
Centrifugal fans and pumps often follow approximate affinity laws: torque varies with speed squared and power with speed cubed, assuming similar operating conditions and fluid properties.
These relationships are not universal system guarantees. Static pressure, control valves, process changes, and operating away from the expected curve can alter actual loading.
Above base speed, a drive may operate the motor in a field-weakening region where available torque falls as speed increases. Check both power and torque limits.
Also verify maximum mechanical speed, bearing limits, vibration, and the driven machine’s speed rating. Electrical capability alone does not establish safe mechanical operation.
Size the variable frequency drive alongside the motor
A variable frequency drive, or VFD, controls motor speed and torque, but its current and overload ratings can constrain the performance of a larger motor.
Compare required current, peak duration, and repetition rate with the drive’s continuous and overload ratings. Confirm the applicable duty class and operating conditions with the supplier.
Evaluate low-speed torque control, encoder requirements, supply voltage, enclosure, ambient temperature, and installation altitude. Derating can reduce available drive current in demanding conditions.
During deceleration or overhauling loads, the machine may return energy to the drive. Assess whether a braking resistor, regenerative drive, or longer deceleration time is required.
Check motor insulation compatibility, cable length, bearing-current mitigation, and any required output filters against the motor and drive manufacturers’ installation guidance.
Protection settings also need review. Motor thermal protection should reflect the actual motor, cooling arrangement, and operating profile rather than rely solely on generic defaults.
Compare margins without defaulting to oversizing
Apply a documented margin to uncertain loads, future operating changes, and component tolerances. The appropriate allowance depends on measurement quality and the consequences of failure.
Keep uncertainty margin separate from the motor’s service factor or short-time overload rating. Neither should be treated as unlimited capacity for a recurring duty cycle.
Oversized electric motors can increase purchase cost, starting current, and equipment size. Light loading can also reduce efficiency or power factor, depending on the motor.
Compare alternatives at actual operating points rather than rated efficiency alone. Include expected running hours, electricity price, drive losses, maintenance, and the cost of downtime.
For energy-intensive installations, request efficiency data across the anticipated load and speed range. A higher-efficiency motor is most valuable where operating hours justify its premium.
What technical evaluators should request from suppliers
Provide each supplier with the same duty profile, motor-shaft load data, acceleration requirements, supply characteristics, environmental conditions, and expected operating life for a fair comparison.
Request continuous and peak torque-speed curves for the proposed motor and drive together, including overload duration, repetition limits, cooling assumptions, and applicable derating.
Ask for a thermal assessment of the stated cycle, starting or acceleration calculations, braking requirements, and confirmation of relevant motor and drive standards.
Confirm mechanical interfaces, enclosure protection, hazardous-area certification where required, maintenance provisions, and spare-parts availability. These factors can invalidate an otherwise adequate electrical selection.
Before acceptance, define commissioning measurements for current, speed, acceleration time, and temperature under representative production conditions. Investigate deviations before increasing throughput or duty severity.
Final selection: thermal capacity first, peak capability always
The right motor is one that meets the complete operating profile: continuous thermal demand, transient torque, acceleration, speed range, and the drive’s electrical limits.
Use calculations to narrow the options, then obtain manufacturer confirmation for the real duty cycle. Document assumptions and validate performance under representative load after installation.
Deep Dive
Related Intelligence
 Electric MachineryElectric motors rated IP67 — how deep is the water resistance really tested?Analyst:Chief Civil Engineer
 Electric MachineryElectric Motors in Poultry Ventilation Fans — Higher Efficiency, Lower Dust ToleranceAnalyst:Chief Civil Engineer
 Electric MachineryChina’s Green Smart Ship Tech Rules Impact Marine Equipment ExportAnalyst:Chief Civil Engineer